Angular and Two-Pointer
What is this?
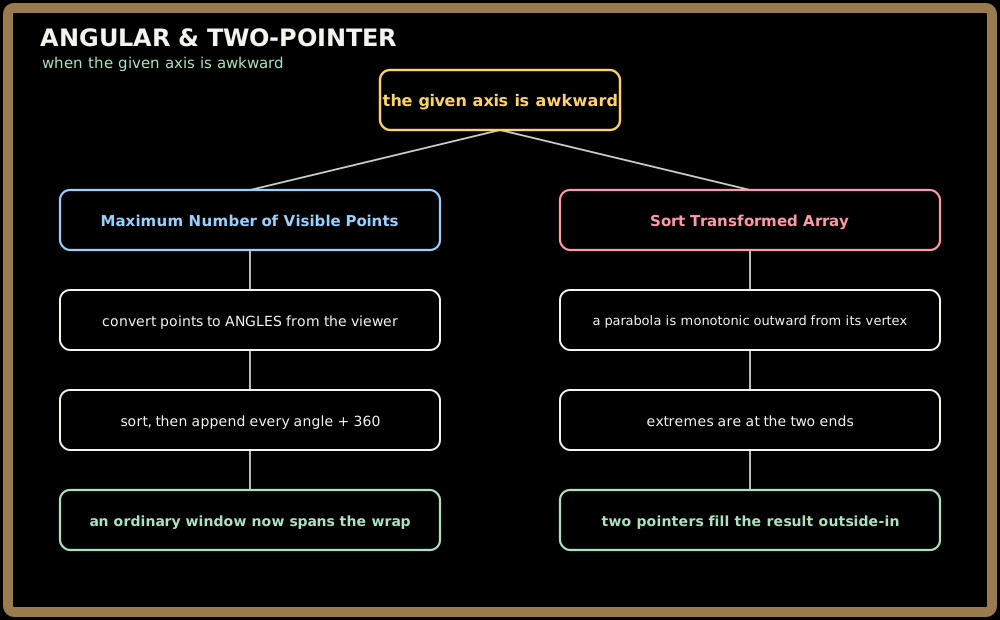
Both problems here are easy once you stop looking at the data you were given and look at a different axis. Points scattered on a plane become a one-dimensional list of angles. A quadratic applied to a sorted array is not sorted — but it is monotonic outward from its vertex, which means the extremes sit at the two ends and can be collected inward.
Neither needs a clever data structure. Both need you to notice which ordering already exists.
💡 Fun fact: the
+ 360duplication is the angular version of a trick that appears throughout the curriculum — linearise a circular problem by writing the data twice. It is the same move that makes circular next-greater-element work by iterating2ntimes with% n, and the same reason a doubled string contains every rotation of itself. Whenever wraparound is the only complication, duplicating the sequence usually removes it entirely.
🔓 The 2 problems in this chapter are free. Sign in with Google or Microsoft to start solving.
The one-line idea: find the axis on which the data is already ordered — the angle from the viewer, or the distance from a parabola's vertex — and a standard linear technique applies without any new machinery.
1. Points become angles
import math
angles = []
same = 0
for x, y in points:
    if [x, y] == location:
        same += 1                      # a point AT the viewer is always visible
        continue
    angles.append(math.degrees(math.atan2(y - location[1], x - location[0])))

angles.sort()
angles += [a + 360 for a in angles]    # linearise the wraparound

best = left = 0
for right in range(len(angles)):
    while angles[right] - angles[left] > angle:
        left += 1
    best = max(best, right - left + 1)
return best + same
Three details decide correctness. atan2 handles all four quadrants and the vertical case, where a naive atan(y/x) divides by zero. Points located exactly at the viewer have no defined angle and are visible regardless — count them separately and add at the end. And the duplication must happen after sorting, so the appended copies stay in order.
Floating point deserves a word: comparing angles[right] - angles[left] > angle on values produced by atan2 can misjudge a point exactly on the boundary. Where the problem's tolerance matters, compare with a small epsilon.
2. A parabola is monotonic from its ends
Applying f(x) = ax² + bx + c to a sorted array does not give a sorted result — but the shape is predictable. When a > 0 the parabola opens upward, so the largest values are at the two ends of the input and the smallest is somewhere in the middle. When a < 0 it is the reverse.
So fill the output from the outside in:
res = [0] * len(nums)
i, j = 0, len(nums) - 1
write = len(nums) - 1 if a >= 0 else 0
step = -1 if a >= 0 else 1
while i <= j:
    fi, fj = f(nums[i]), f(nums[j])
    if (a >= 0) == (fi > fj):          # take whichever end wins for this orientation
        res[write] = fi; i += 1
    else:
        res[write] = fj; j -= 1
    write += step
return res
a == 0 makes it linear, and folding it in with a >= 0 handles it correctly — the values are then monotonic in the same direction as the input, and the comparison still picks the right end.
3. A 30-second worked example (the wrap)
Angles at 350° and 10°, with a field of view of 30°. On the raw sorted list [10, 350] the gap reads as 340° and the window sees one point.
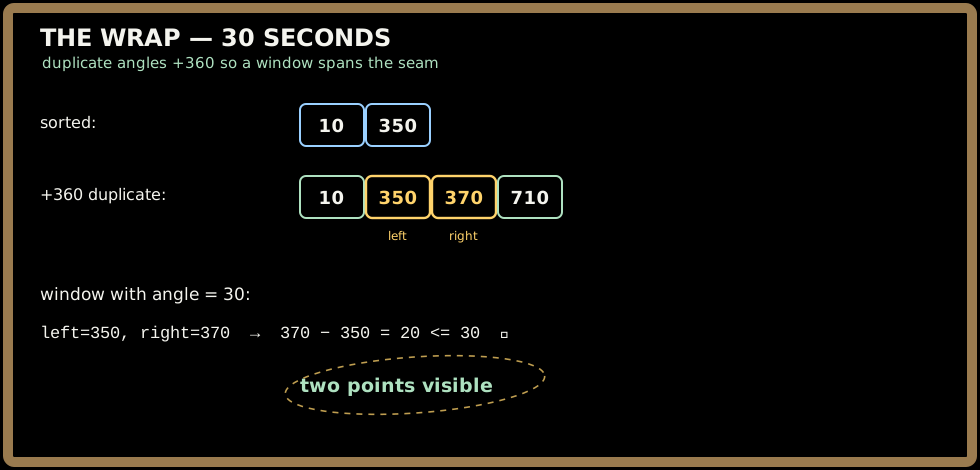
The two points are 20° apart across the zero mark, and the duplication is what lets a left-to-right window see it. Without it, no window over [10, 350] ever contains both.
4. Where you'll actually meet this
- Games and simulation. Field-of-view and line-of-sight queries — how many entities fall inside a cone from the player.
- Robotics. LIDAR and sensor sweeps, where readings are naturally angular and the zero crossing is a real source of bugs.
- Radar and surveillance. Counting contacts within a bearing window.
- Computational geometry. Angular sweeps underpin convex hull and visibility algorithms.
- Signal processing. Applying a quadratic response curve to sorted measurements and needing the result ordered.
5. Problems in this chapter
▶ Maximum Number of Visible Points
Most points visible within a fixed angular field of view. Convert to angles with atan2, sort, append every angle + 360, then run an ordinary window; count points at the viewer separately.
Pattern: angular window with wraparound duplication. Target: O(n log n) time, O(n) space.
▶ Sort Transformed Array
Apply ax² + bx + c to a sorted array and return the sorted result. Two pointers fill outside-in, because a parabola is monotonic outward from its vertex.
Pattern: two-pointer fill by orientation. Target: O(n) time — better than the O(n log n) transform-then-sort.
6. Common pitfalls 🚫
- Using
ataninstead ofatan2. It loses the quadrant and divides by zero on vertical alignments. - Forgetting points at the viewer. They have no angle, are always visible, and must be added after the window.
- Duplicating before sorting. The appended copies must preserve order or the window breaks.
- Ignoring floating-point tolerance on points exactly at the field-of-view boundary.
- Sorting after the transform. Correct, and
O(n log n)for a problem that isO(n). - Handling
a == 0as a special case. Folding it in witha >= 0works; a separate branch is easy to get backwards. - Writing the output forwards when
a > 0. The largest values come first, so the write pointer must start at the end and move backwards.
7. Key takeaways
- Change the axis. Points become angles; a parabola becomes distance from its vertex.
- Duplicate to linearise a circle.
+ 360here,2niterations elsewhere — the same idea. atan2, always, for anything angular.- Handle the degenerate point — one located exactly at the viewer — outside the main loop.
- A parabola's extremes are at the input's ends, which is what makes an outside-in fill correct.
- Two pointers beat a sort whenever the output ordering can be derived rather than computed.
- Why interviewers like it: both problems look geometric and are solved by ordinary linear techniques once the right ordering is spotted. That spotting is the whole test.
Order: Maximum Number of Visible Points → Sort Transformed Array.
Maximum Number of Visible Points
Core idea: You stand at a fixed
locationand can rotate your gaze freely, but your eyes only span a fixedangle-wide cone at a time. A point is visible if its direction from you falls inside that cone. The direction of each point is its polar angle —atan2(dy, dx)— and rotating your gaze is just sliding that fixed-width window of angles around the circle. So the 2D "what can I see" question collapses to a 1D one: sort all the polar angles, then slide a window of widthangleand count the most angles it ever covers. Two wrinkles make it interview-worthy. (1) Wrap-around: angles live on a circle (atan2returns(-180°, 180°]), so a window can straddle the±180°seam. Fix it by duplicating the sorted list with every angle+360— now any circular window appears as a plain contiguous window somewhere in the doubled array. (2) Points exactly atlocationhave no direction at all (atan2(0,0)is meaningless), but they're always visible no matter where you look — so count them separately and add them at the end. Sorting dominates: O(n log n).
Problem, rephrased
You're installing a surveillance camera on a fixed mount in a plaza. The mount can rotate to face any direction, but the lens spans only a fixed wedge of view at a time. You're given points, a list of [x, y] coordinates of the assets to watch, an integer angle — the camera's field of view in degrees — and the mount position location = [x, y]. The mount is fixed: you choose a facing, not a position.
Return the maximum number of points the camera can capture in a single facing. A point is in frame if the angle between the viewing direction and the direction from location to that point is at most angle / 2 on either side — equivalently, if its direction falls inside some angle-wide wedge. Directions live on a full circle, so the best wedge may point across the seam where +180° meets -180°. A point sitting exactly at location has no direction at all and is always counted, whichever way the camera faces.
Strip the story away and this is LeetCode 1610 — Maximum Number of Visible Points: given points (a list of [x, y]), an integer angle, and your location = [x, y], return the maximum number of points visible through an angle-degree field of view that you may rotate to any orientation from location; points equal to location always count.
| Input | Means | Output |
|---|---|---|
points=[[2,1],[2,2],[3,3]], angle=90, location=[1,1] |
All three lie within a 90° wedge | 3 |
points=[[2,1],[2,2],[3,4],[1,1]], angle=90, location=[1,1] |
One point is at your location (always seen) + 3 in a 90° wedge | 4 |
points=[[1,0],[2,1]], angle=13, location=[1,1] |
The two directions differ by more than 13° | 1 |
The interesting word is angle — it turns a geometry problem into a windowing problem the moment you realize a viewing direction is just a position on the circle of polar angles.
Sign in to continue reading
The rest of this lesson is available with a free account. Signing in with Google or Microsoft is free.
Sign in to read the full lesson